Mirror AI
Company developing Reflexible, a safety-critical control layer that compiles high-level intent into verified deterministic robot control code.
Coverage
3 November 2026
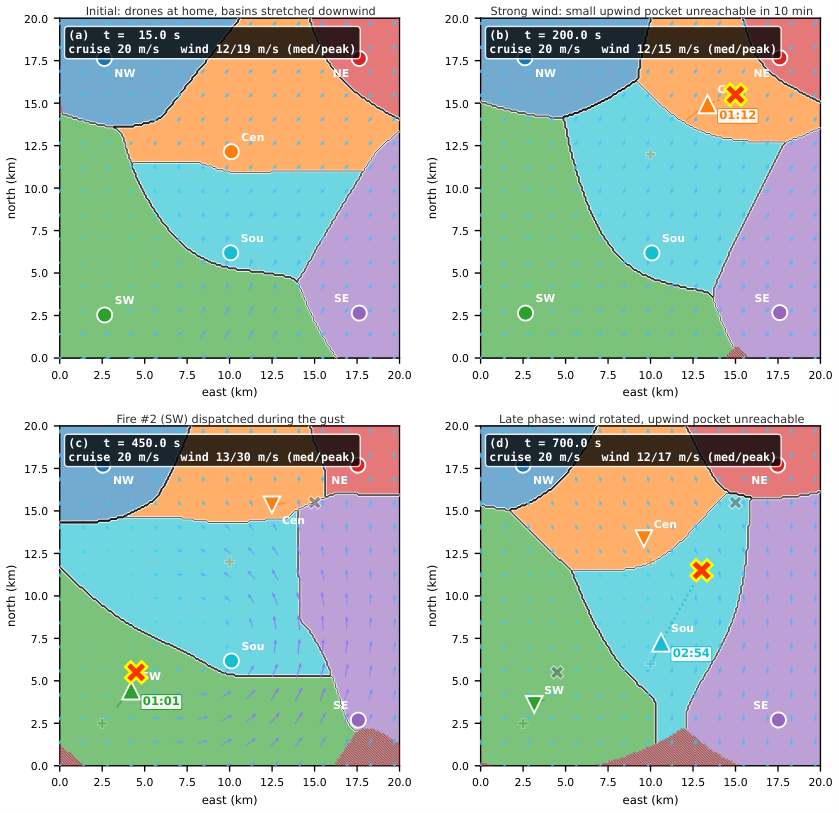
Formal safety checking for robots, fast enough for the control loop: 112 Hz on a GPU, 66 Hz on an embedded board
Hamilton-Jacobi reachability, a formal method normally computed offline, runs online in these benchmarks; no physical robot has flown with it yet.
arXiv (preprint)