RD-RRT*
Path planning method
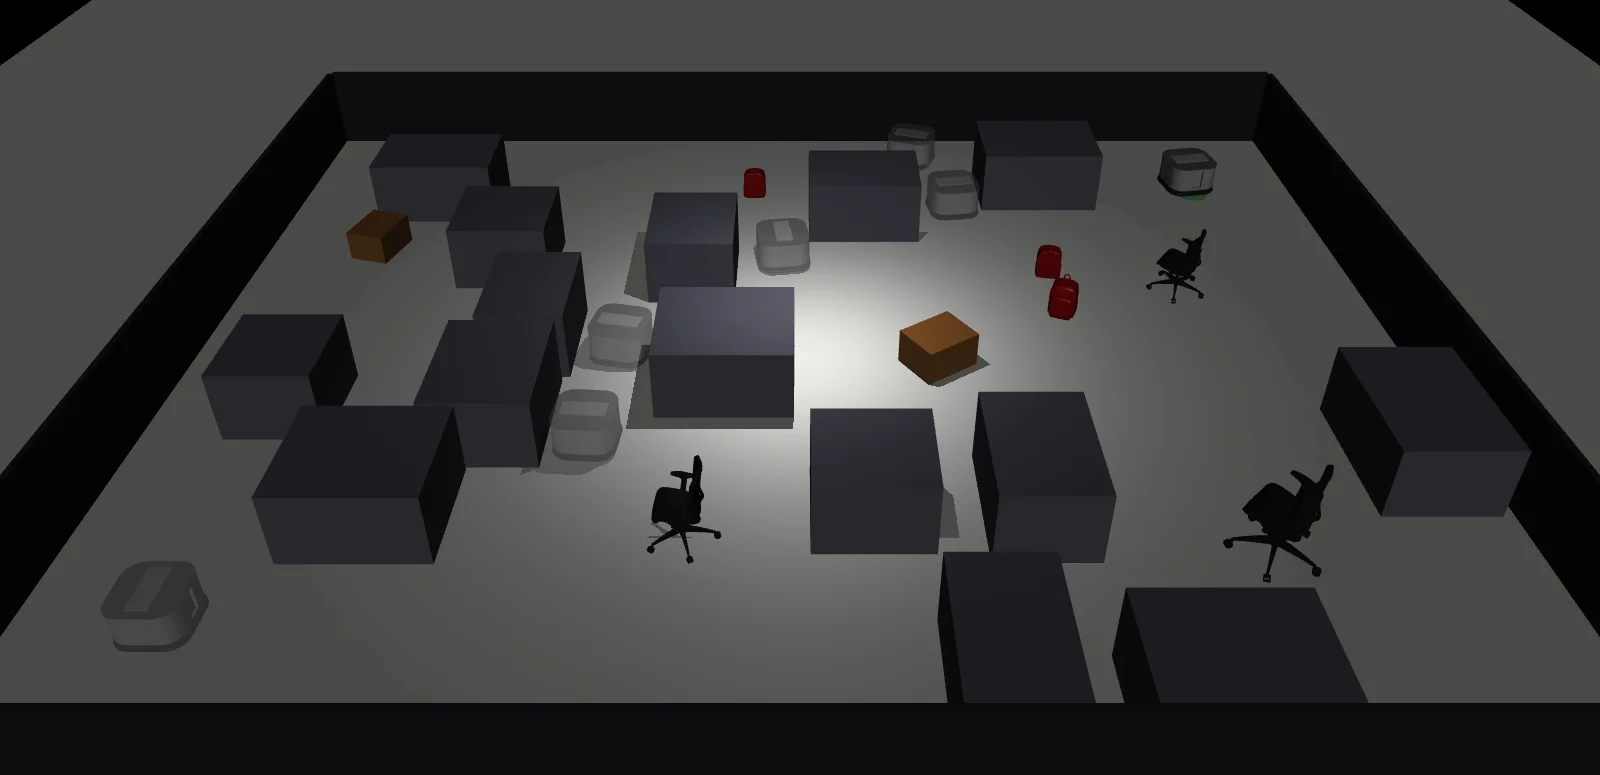
Path planner that extends RRT* to find the paths with the lowest risk of collision.
Description from arXiv Robotics (cs.RO)
Stories
17 November 2026
RD-RRT* plans robot paths with the lowest chance of a collision

Path planning method
Path planner that extends RRT* to find the paths with the lowest risk of collision.
Description from arXiv Robotics (cs.RO)
17 November 2026
RD-RRT* plans robot paths with the lowest chance of a collision